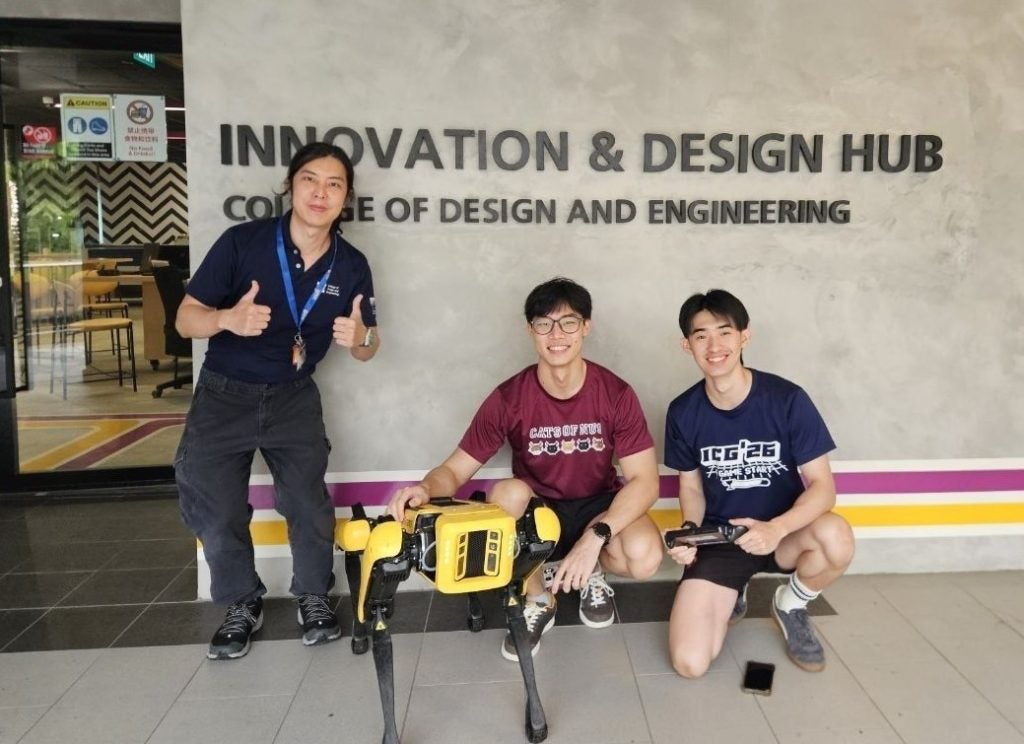
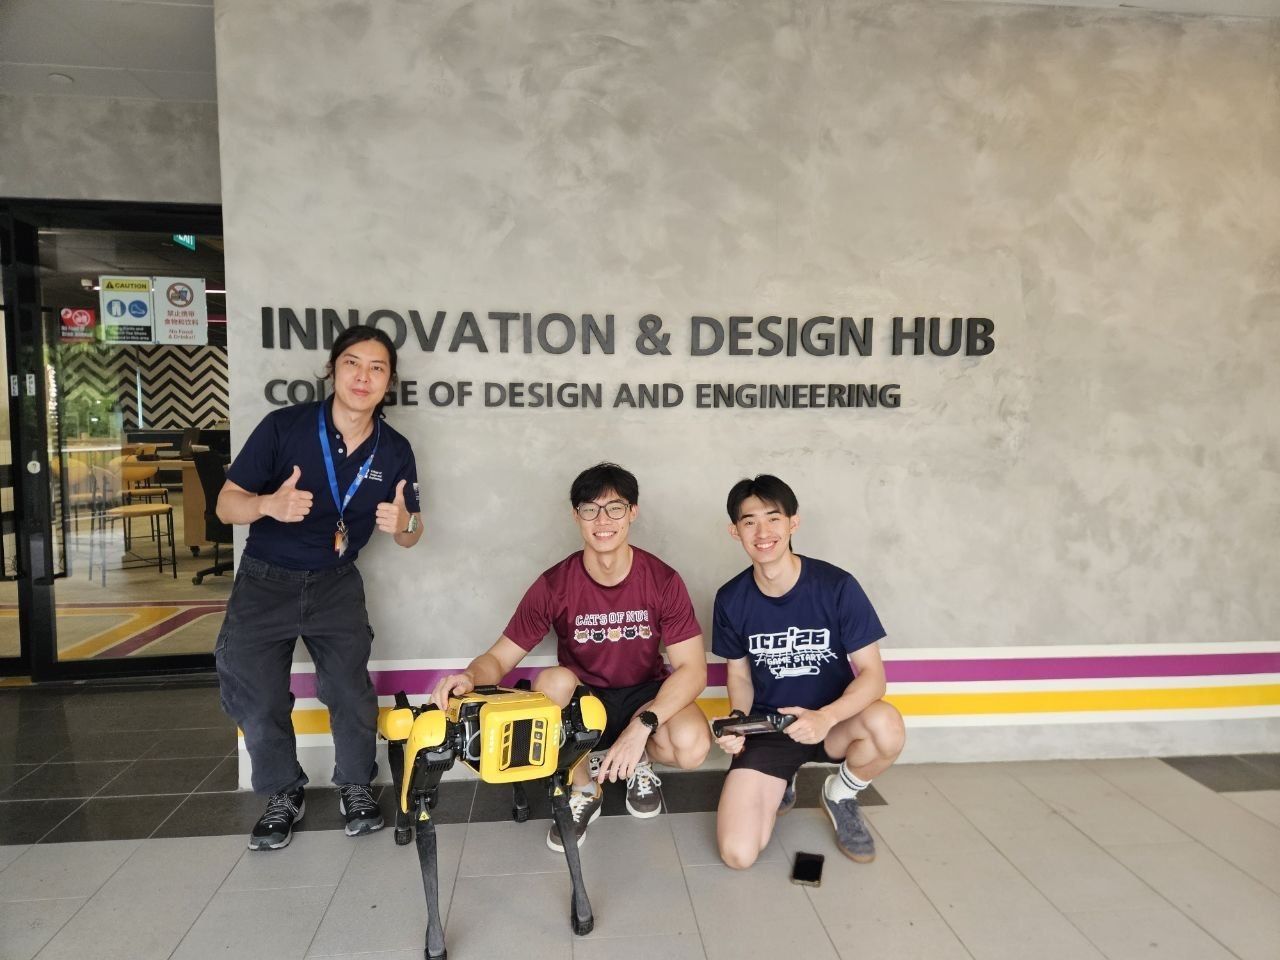
When Mechanical Engineering students Kow Ming Yuan and Wang Yizhang signed up to spend their summer working with Spot, a sophisticated robot dog made by Boston Dynamics, they hadn't planned on becoming robot vets.
But their four-legged patient was in a sorry state. Its batteries were dead, one of its legs was malfunctioning, and it couldn't even sit down properly, let alone go for a walk.
Over the next three months, they would diagnose faults, investigate Spot's inner workings and carry out delicate electronic surgery. By the end of the summer, their efforts had paid off: Spot was back on its feet, walking, climbing stairs and navigating buildings independently.
The two students, now in their second year at CDE, took on the challenge as part of the Undergraduate Research Opportunities Programme (UROP), which allows students to work on research projects under the guidance of academic supervisors.
"Boston Dynamics leads the robotics field, so working hands-on with one of their robots was too good to pass up," said Yizhang. "But mostly, robot dogs are cool."
Spot had previously been used for research into robotic inspection of buildings at CDE's Built Environment Automation & Digitalization (BEADZ) Lab. After the project ended, Professor Justin Yeoh (Department of Civil and Environmental Engineering) made the robot available to students, giving undergraduates hands-on access to equipment usually reserved for research.
Putting the spring back in Spot's step would be anything but straightforward.
Yizhang, who took the lead on troubleshooting the batteries, discovered that every cell inside the two battery packs had deteriorated beyond recovery. Both packs would need to be rebuilt.
"Because the robot is proprietary, Ming Yuan and Yizhang had little documentation, no access to its diagnostic data and very little specialised repair equipment," said supervisor Nicholas Chew, an instructor at CDE's Engineering Design and Innovation Centre.
Nonetheless, he said, "that didn’t stop them".
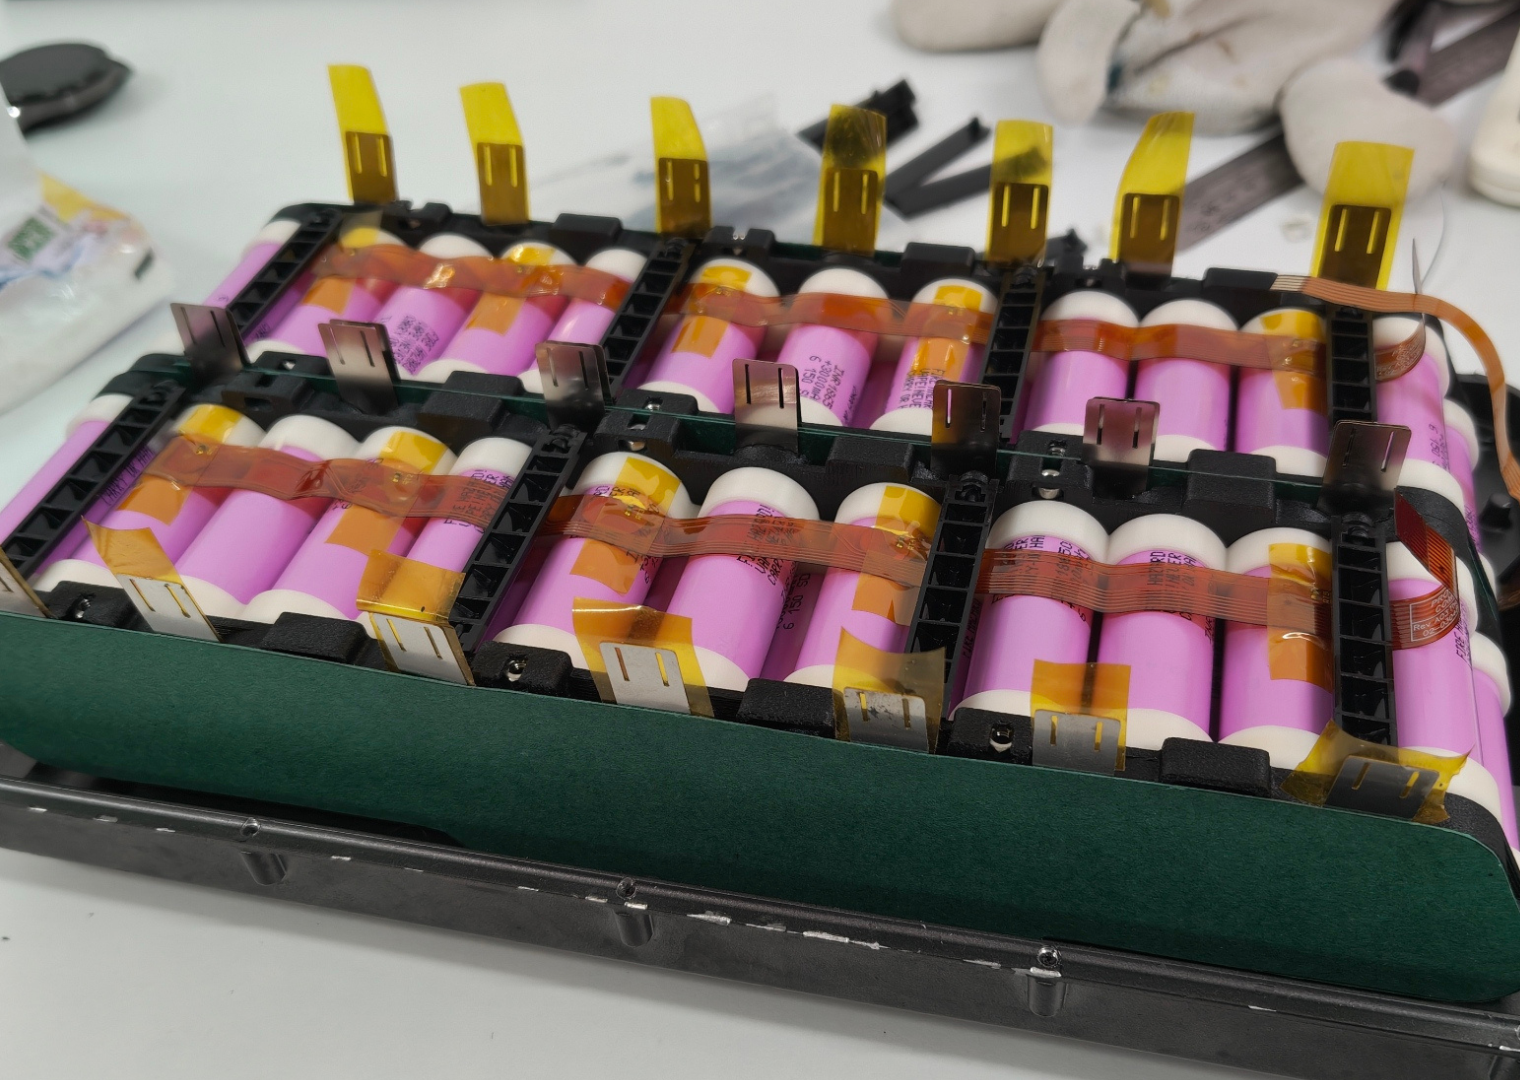
Yizhang, who took the lead on troubleshooting the batteries, discovered that all 112 cells in the two battery packs had deteriorated beyond recovery. Both packs would need to be rebuilt.
With no schematics, he probed the BMS circuitry by hand to reverse engineer the core functionalities, which was essential in helping him plan a safe disassembly and rebuild of the high-power packs.
With help from iDP teaching assistant Royston Shieh, they carefully opened the sealed battery packs, worked out their internal construction and replaced all 112 battery cells. They also designed and fabricated new components, including 3D-printed holders and metal connectors.
Meanwhile, Ming Yuan was tackling an equally stubborn problem with one of Spot's rear legs. The leg could move normally while the robot was powered on but malfunctioned whenever the system restarted.
To diagnose the issue, Ming Yuan wrote software to monitor all 12 joint angles in real time using the ROS2 framework. Over six weeks, the students systematically tested and swapped components, down to the motor drivers and sensors inside each actuator, eventually tracing the fault to a single joint position sensor.
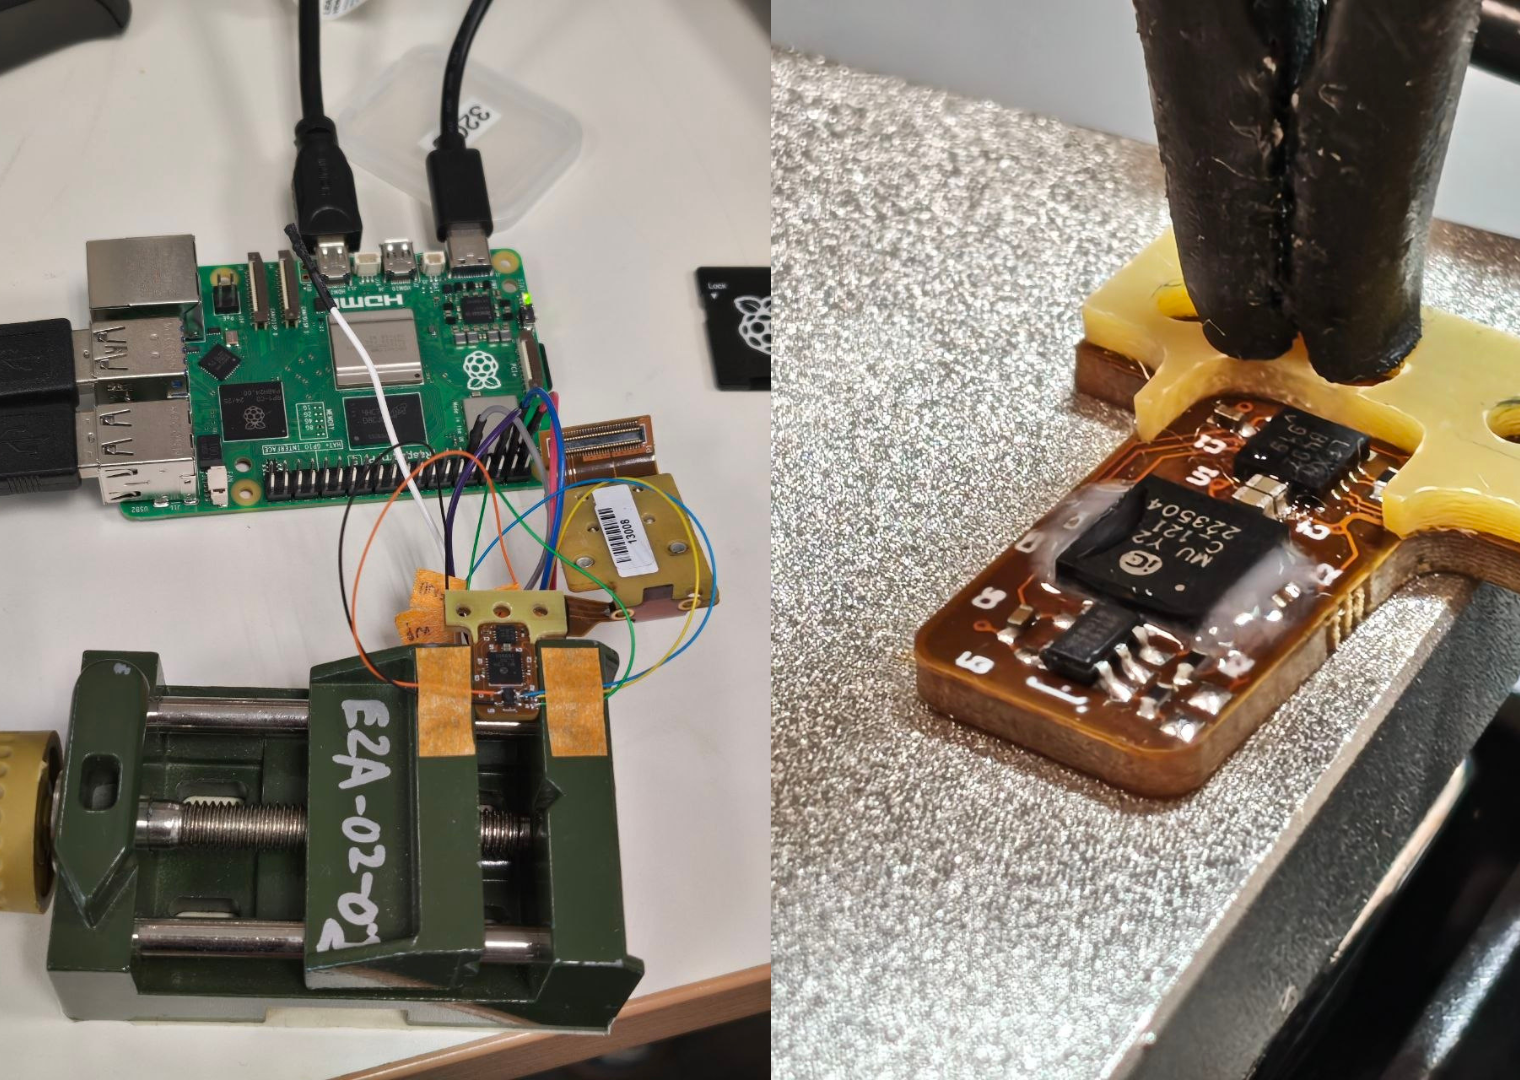
Replacing it was no trivial task. The team designed a custom circuit board to read out and back up the sensor’s factory calibration data in case it was corrupted during the repair, then micro-soldered the tiny replacement encoder onto the original board.
“Every step meant intensive research and trying to understand the original design intent, so that our repairs wouldn’t compromise how the robot was meant to perform,” said Yizhang. “We even spent a few days researching the specific grease used in the harmonic actuators before re-lubricating. Precision hardware like this is sensitive to the smallest things.”
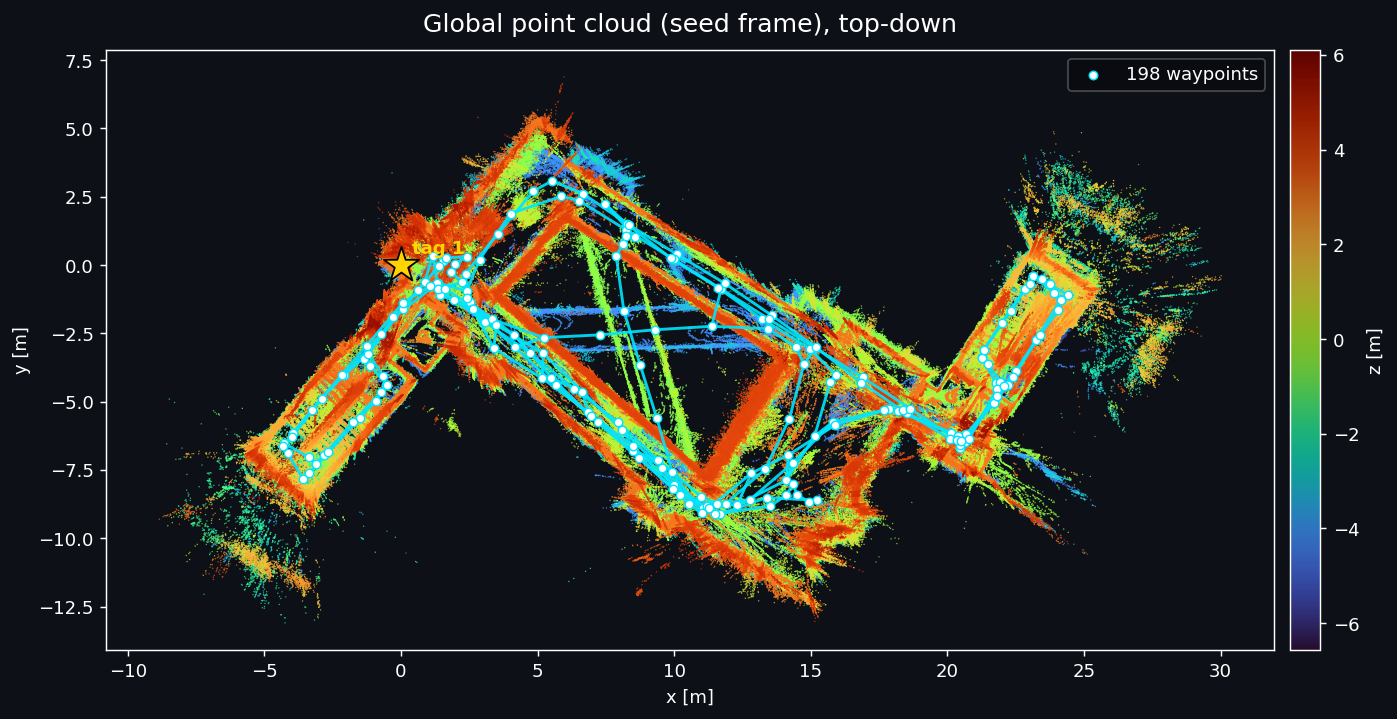
With both problems resolved, the students put Spot through its paces, successfully testing its ability to walk, climb stairs and complete autonomous navigation and mapping missions around CDE's E2A building. In the time remaining after the repairs, Ming Yuan also developed a behaviour tree for Spot, a modular decision-making framework that lets the robot choose and sequence custom actions based on what its sensors detect.
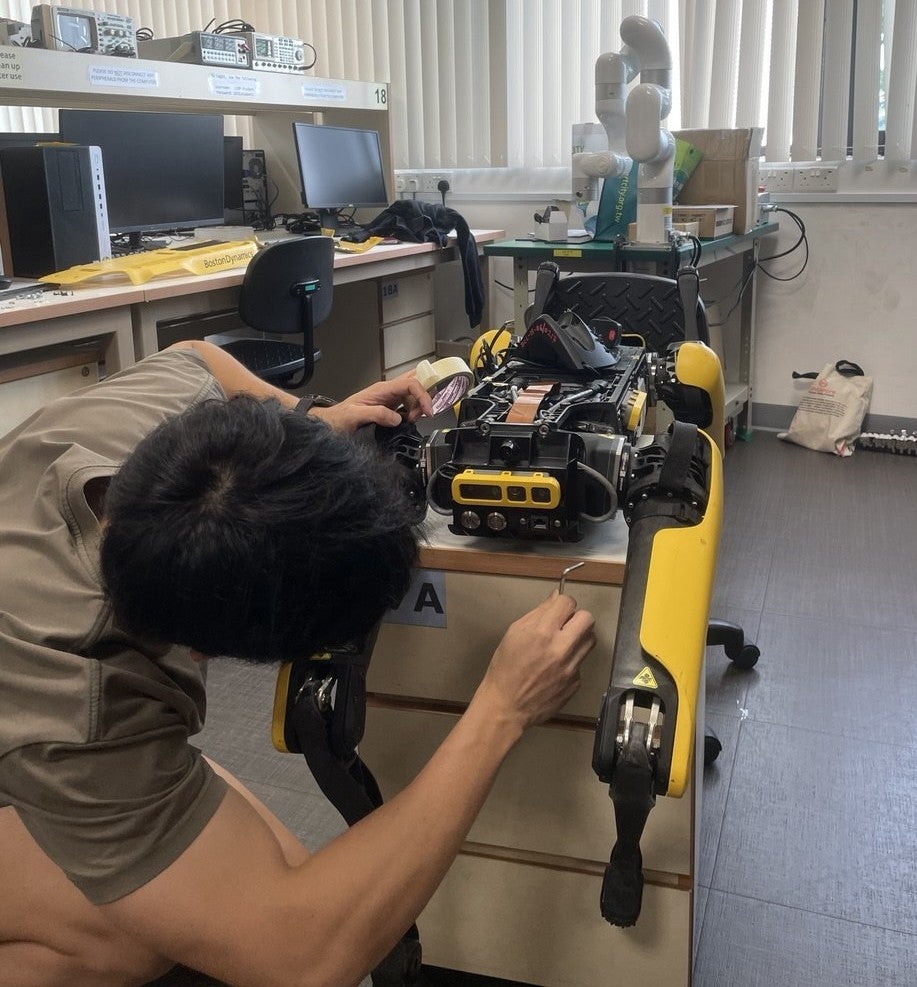
"There's something about a working piece of hardware that gives you an extra kick compared to software," said Yizhang. "You can physically interact with the result of your work: walk the dog, make it dance, or watch it flip itself over after a bad fall."
"Given where we started, with dead batteries, an undocumented system, and a robot that couldn't even sit, we were a little surprised we actually got it fixed. Watching it stand up and walk on its own for the first time made all the efforts worth it."
For Ming Yuan, the challenges they faced were also what made the experience so valuable.
"The more constrained or challenged you are, the more opportunity it gives you to grow," he said, reflecting on how the lack of documentation forced them to understand the robot's mechanical, electrical and software systems in depth.
Nicholas Chew, their supervisor, was particularly impressed by the students' resourcefulness and approach to managing risk.
"What impressed me most was their discipline: they took risks only after doing everything they could to reduce them," he said. "Real-world engineering needs that mix of resourcefulness, patience and rigour, and I think it's the most valuable thing they're taking away from this project."
Find out more about Spot here(opens in new tab).