Biography
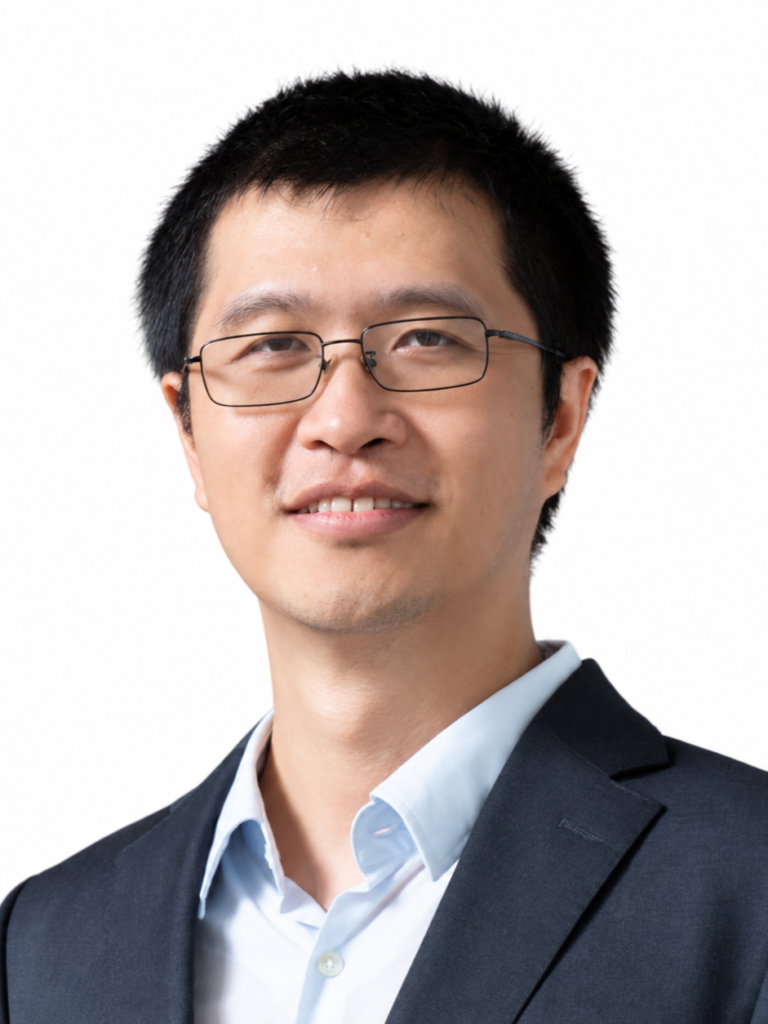
Kaidi Yang is an ETH-trained PhD with experience in transportation, AI, and robotics. His research focuses on trustworthy AI for human-oriented intelligent systems, with particular emphasis on future mobility. His research spans two complementary directions: (i) responsible data analytics, including privacy-preserving transportation data collaboration, and (ii) safe and human-centred decision-making for complex systems involving humans and autonomous agents. Before joining NUS, he was a postdoctoral scholar with the Autonomous Systems Lab at Stanford University. He received his PhD from ETH Zurich in 2019, an M.Sc. in Control Science and Engineering from Tsinghua University in 2014, and dual bachelor’s degrees in Automation and Mathematics from Tsinghua University in 2011.
Qualifications
- Ph.D., Civil and Environmental Engineering (specialised in Transportation), ETH Zurich, 2019
- M.Sc., Control Science and Engineering, Tsinghua University, 2014
- B.Sc. (Dual), Pure and Applied Mathematics, Tsinghua University, 2011
- B.Eng., Automation, Tsinghua University, 2011
Position Held
- Assistant Professor, National University of Singapore, 2022 – Present
- Postdoctoral Scholar, Stanford University, 2019-2022
Selected Honours & Awards
- Best Paper Award, the 7th International Symposium on Multimodal Transportation (ISMT), 2025
- Postdoc Mobility Fellowship, Swiss National Science Foundation (2021-2022)
- Early Postdoc Mobility Fellowship, Swiss National Science Foundation (2019-2020)
- Best Student Paper Award, IEEE Intelligent Transportation Systems Conference (2020)
- Chinese Government Award for Outstanding Self-Financed Students Abroad (2019)
- Best Paper Award, OMEGA: The International Journal of Management Science (2019)
- Student Fellow for the 22nd International Symposium for Transportation and Traffic Theory (2017)
Professional Activities
- Associate Editor, IEEE Transactions on Intelligent Transportation Systems, 2026 – present
- Action Editor, Transactions on Machine Learning Research, 2026 – present
- Guest Editor, Transportation Research Part A, 2025
- Guest Editor, Multimodal Transportation, 2025
Research Interests
- Intelligent Transportation Systems
- Connected and Automated Vehicles
- Traffic Flow Theory and Control
- Privacy-Preserving Data Collaboration
- Trustworthy AI
Selected Publications
- Zhou, Jingyuan, Zhicheng Wang, and Kaidi Yang*. “Delay-Aware Multi-Agent Reinforcement Learning for Mixed-Autonomy Platoon Control. ” Transportation Research Part C: Emerging Technologies (in press).
- Zhu, Jichen, Qiqing Wang, Kaidi Yang*, and Xiaoguang Yang. “Schedule adherence oriented traffic signal control for large-scale scheduled vehicle operations: A multi-agent reinforcement learning approach.” Transportation Research Part C: Emerging Technologies 189 (2026): 105720.
- Wang, Wenyang, Qihang Chen, Li Chen, and Kaidi Yang*. “Safe reinforcement learning-based speed scheduling for an unmanned photovoltaic-battery vessel under uncertainties of solar irradiance and sea waves.” Energy Conversion and Management 360 (2026): 121580.
- Wang, Qiqing, Haokun Yu, and Kaidi Yang*. “Fostering data collaboration in digital transportation marketplaces: The role of privacy-preserving mechanisms.” Transportation Research Part A: Policy and Practice 209 (2026): 105018. (Also presented at ISTTT 2026)
- Zhou, Jingyuan, Yuexuan Wang, and Kaidi Yang*. “Neural Vector Lyapunov–Razumikhin Certificates for Delayed Interconnected Systems.” Proceedings of the 43rd International Conference on Machine Learning (ICML), PMLR 306, 165935–165956, 2026.
- Wang, Yuexuan, Jingyuan Zhou, and Kaidi Yang*. “Hierarchical Decision Making with Structured Policies: A Principled Design via Inverse Optimization.” Proceedings of the 43rd International Conference on Machine Learning (ICML), PMLR 306, 133020–133043, 2026.
- Tianxiang Chen, Jingyuan Zhou, Longhao Yan, and Kaidi Yang*. “RBCBF: Decoding Time Safety Alignment via Risk Guided Rollback and Barrier Control.” Proceedings of the 43rd International Conference on Machine Learning (ICML), PMLR 306, 18627–18653, 2026.
- Zhou, Jingyuan, Longhao Yan, Jinhao Liang, and Kaidi Yang*. “Enforcing cooperative safety for reinforcement learning-based mixed-autonomy platoon control.” IEEE Transactions on Intelligent Transportation Systems 27, no. 1 (2025): 1592-1605.
- Liang, Jinhao, Chaopeng Tan, Longhao Yan, Jingyuan Zhou, Guodong Yin, and Kaidi Yang*. “Interaction-aware trajectory prediction for safe motion planning in autonomous driving: A transformer-transfer learning approach.” IEEE Transactions on Intelligent Transportation Systems (2025).
- Shi, Yuqi, Kaidi Yang*, and Xiaoguang Yang. “Adaptive multi-SWAL: Real-time intersection control with flexible lane design.” Transportation Research Part C: Emerging Technologies 186 (2026): 105586.
- Zhang, Xiaohui, Kaidi Yang*, Jie Sun, and Jian Sun. “Stochastic fundamental diagram modeling of mixed traffic flow: A data-driven approach.” Transportation Research Part C: Emerging Technologies 179 (2025): 105279.
- Zhou, Jingyuan, and Kaidi Yang*. “A parameter privacy-preserving strategy for mixed-autonomy platoon control.” Transportation Research Part C: Emerging Technologies 169 (2024): 104885.
- Wang, Qiqing, and Kaidi Yang*. “Privacy-preserving data fusion for traffic state estimation: A vertical federated learning approach.” Transportation Research Part C: Emerging Technologies 168 (2024): 104743. (Also presented at ISTTT 2024)
- Dakic, Igor, Kaidi Yang*, Monica Menendez, and Joseph YJ Chow. “On the design of an optimal flexible bus dispatching system with modular bus units: Using the three-dimensional macroscopic fundamental diagram.” Transportation Research Part B: Methodological148 (2021): 38-59.
- Kaidi Yang, Mireia Roca-Riu*, and Mónica Menéndez. “An auction-based approach for prebooked urban logistics facilities.” Omega 89 (2019): 193-211. (Best Paper in OMEGA 2019)