JellyBot: underwater surveillance soft robotics
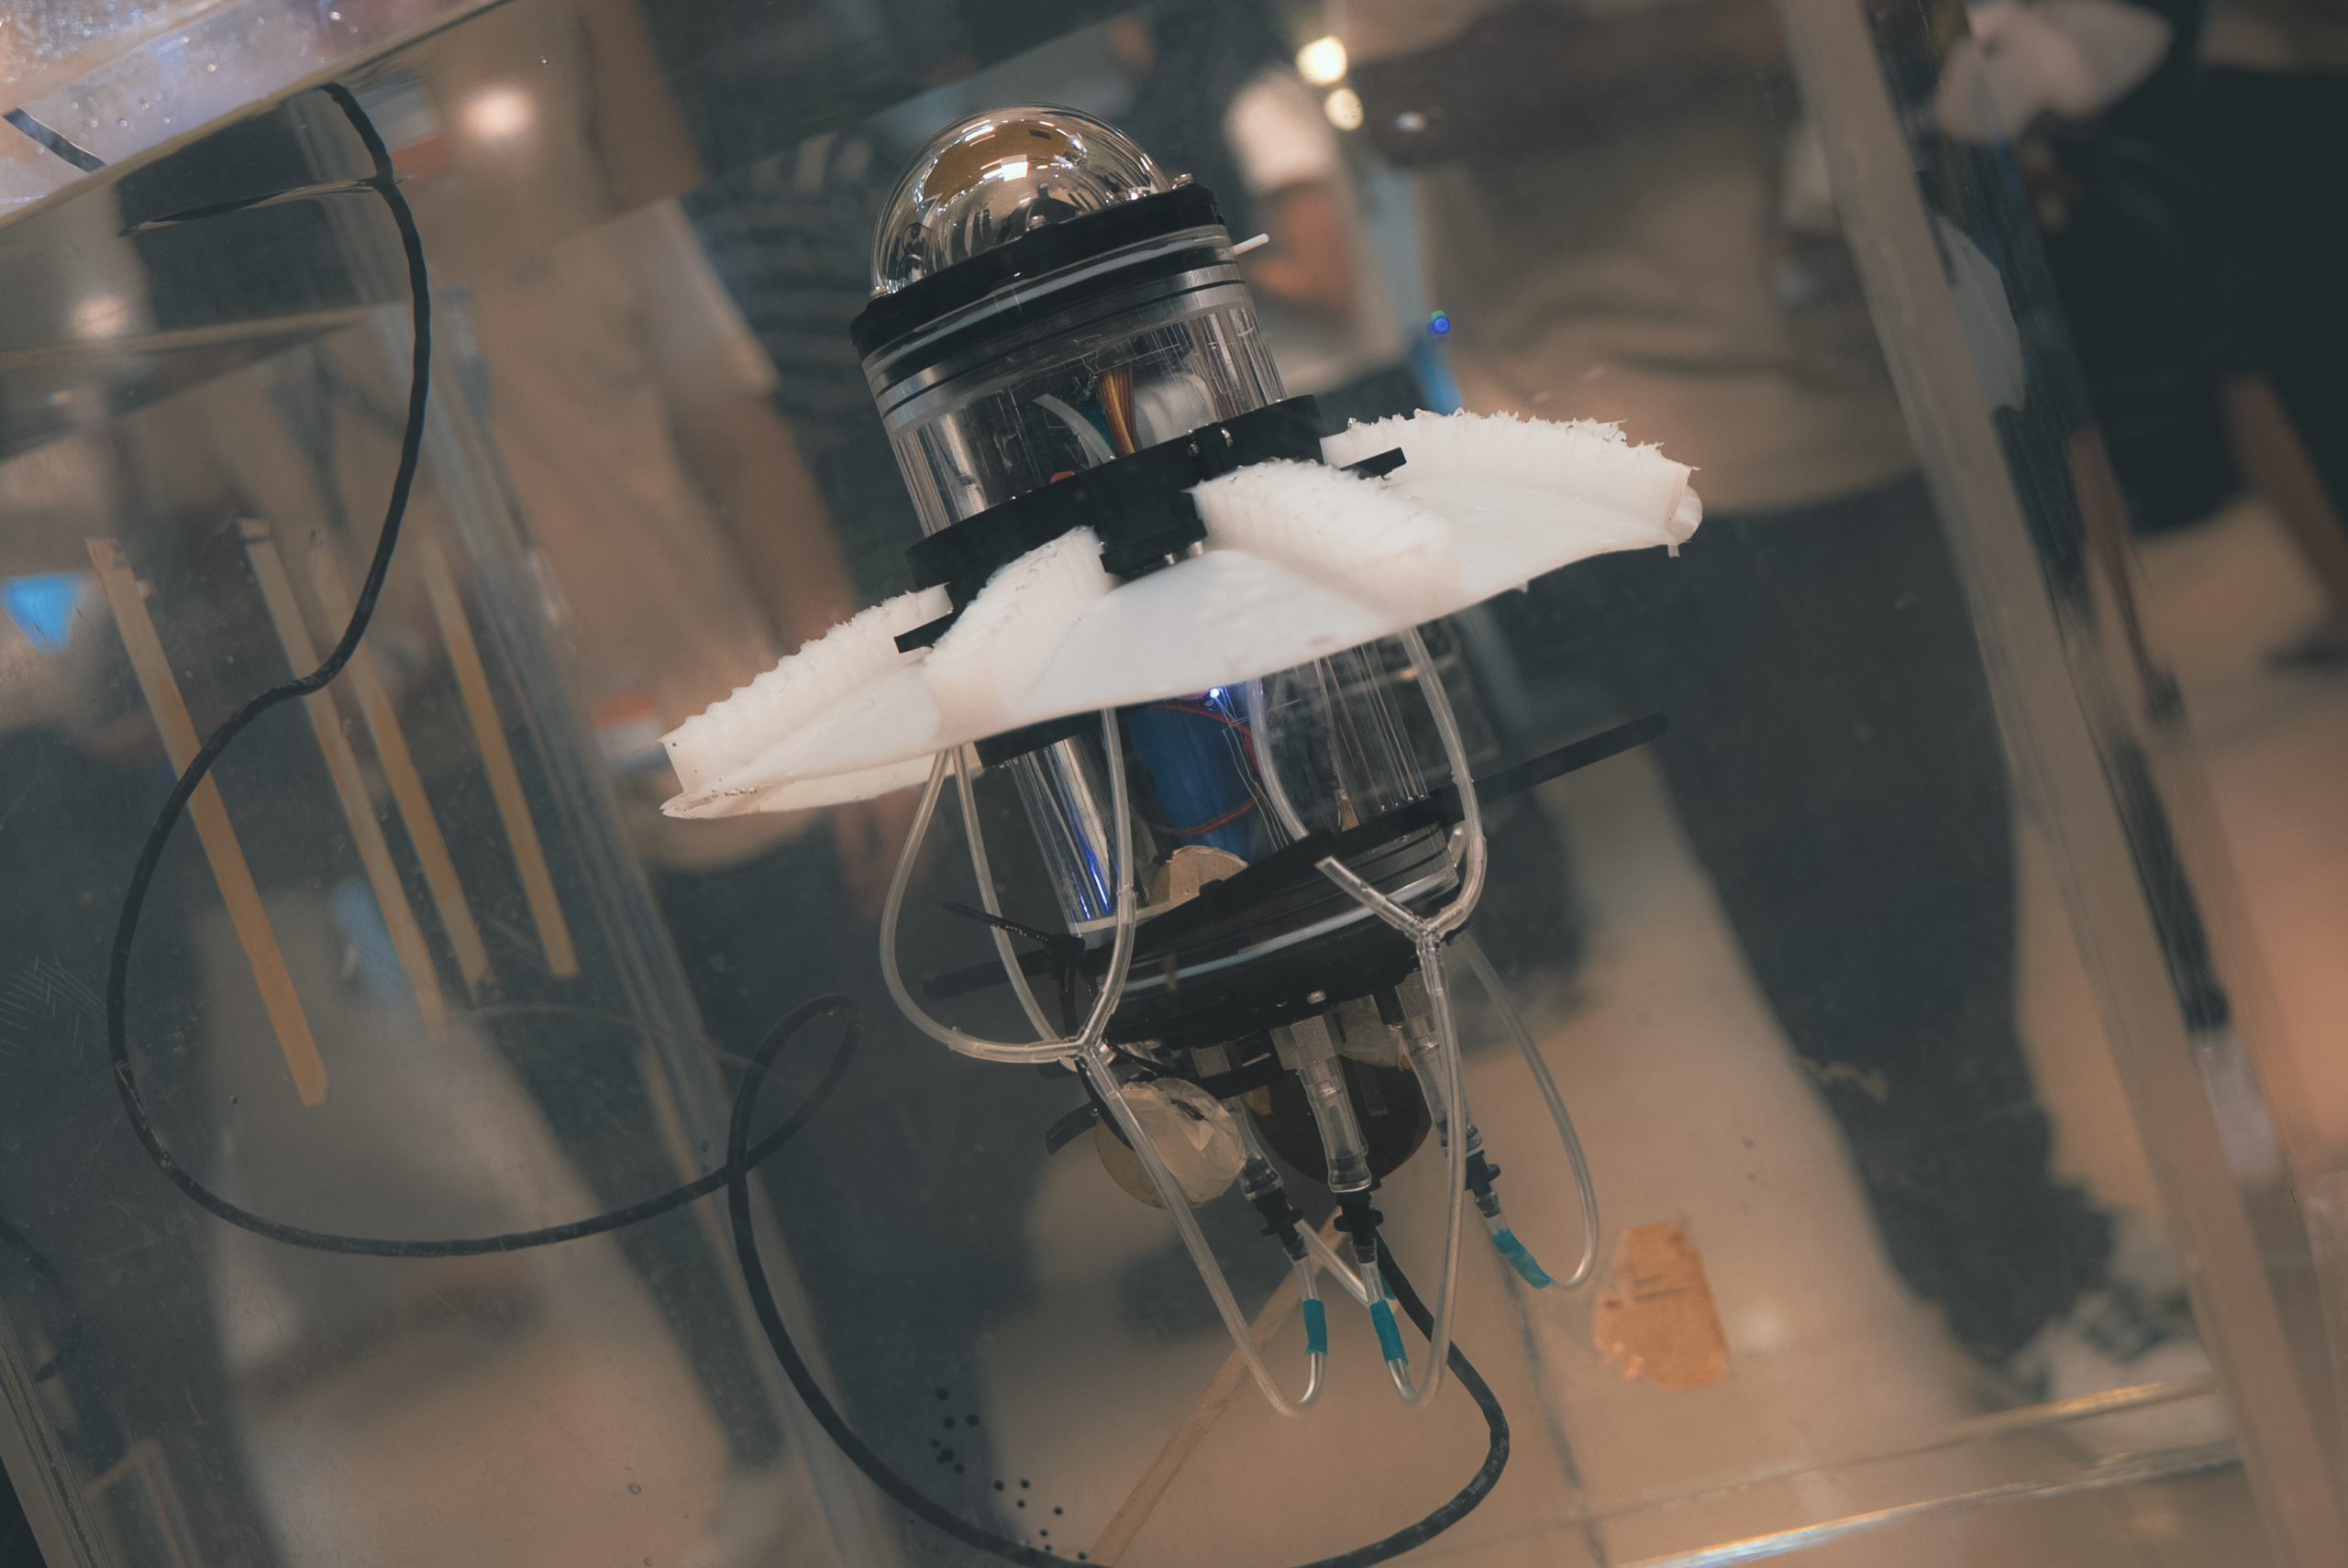
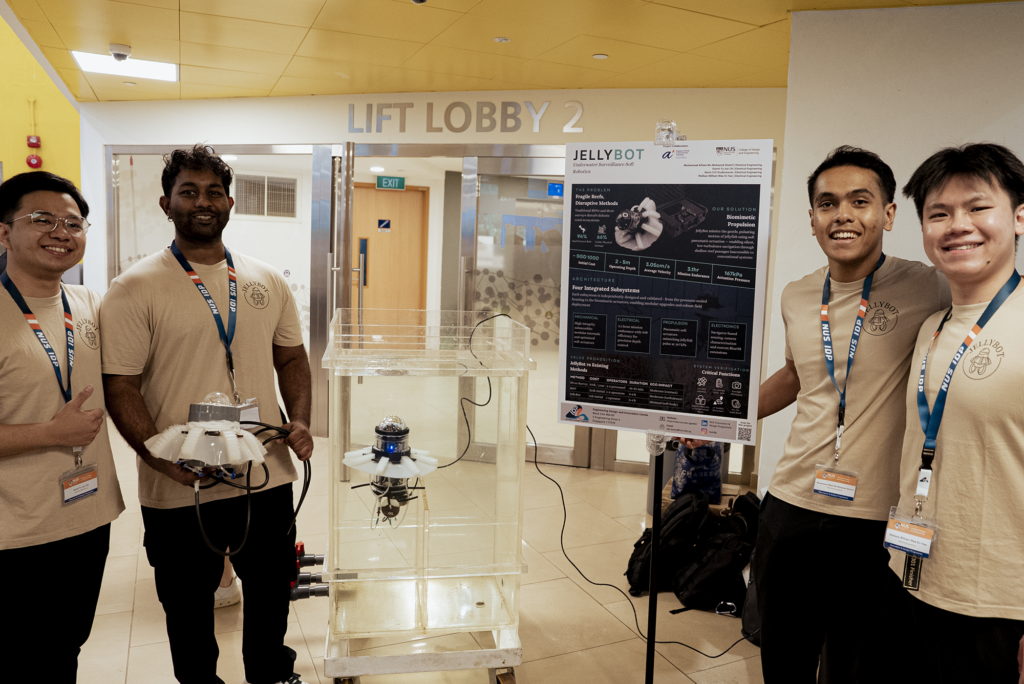
Traditional methods for surveying coral reefs, such as divers and remotely operated vehicles (ROVs), can disturb fragile marine ecosystems through physical contact and turbulence. JellyBot addresses this challenge with a biomimetic underwater robot designed for gentle surveillance of shallow coral reefs.
Inspired by the pulsating motion of a jellyfish, JellyBot uses soft pneumatic actuators to propel itself through the water, enabling quiet, low-turbulence navigation through shallow reef passages that may be inaccessible to conventional systems. Its modular architecture integrates four key subsystems —mechanical, electrical, propulsion and electronics — with features including a pressure-sealed housing, precision depth control, onboard sensing and low-light HD imaging.
Designed to operate at depths of 2 to 5 metres, JellyBot achieves approximately 3.1 hours of mission endurance while requiring only a single operator. With its soft body and biomimetic propulsion, the project demonstrates how soft robotics can provide a less disruptive and more accessible approach to underwater surveillance, supporting the observation of sensitive marine environments while minimising physical impact.
Awards
- National Runner Up, James Dyson Award 2026 (https://www.jamesdysonaward.org/en-SG/2026/project/jellybot)
- Commendation Award, Tan Kah Kee Young Inventors' Award 2026 (https://singaporetkkf.com.sg/tkkyia/)
- James Dyson Foundation Innovation & Design Prize 2026 (https://cde.nus.edu.sg/edic/academics/jdf-prize/)
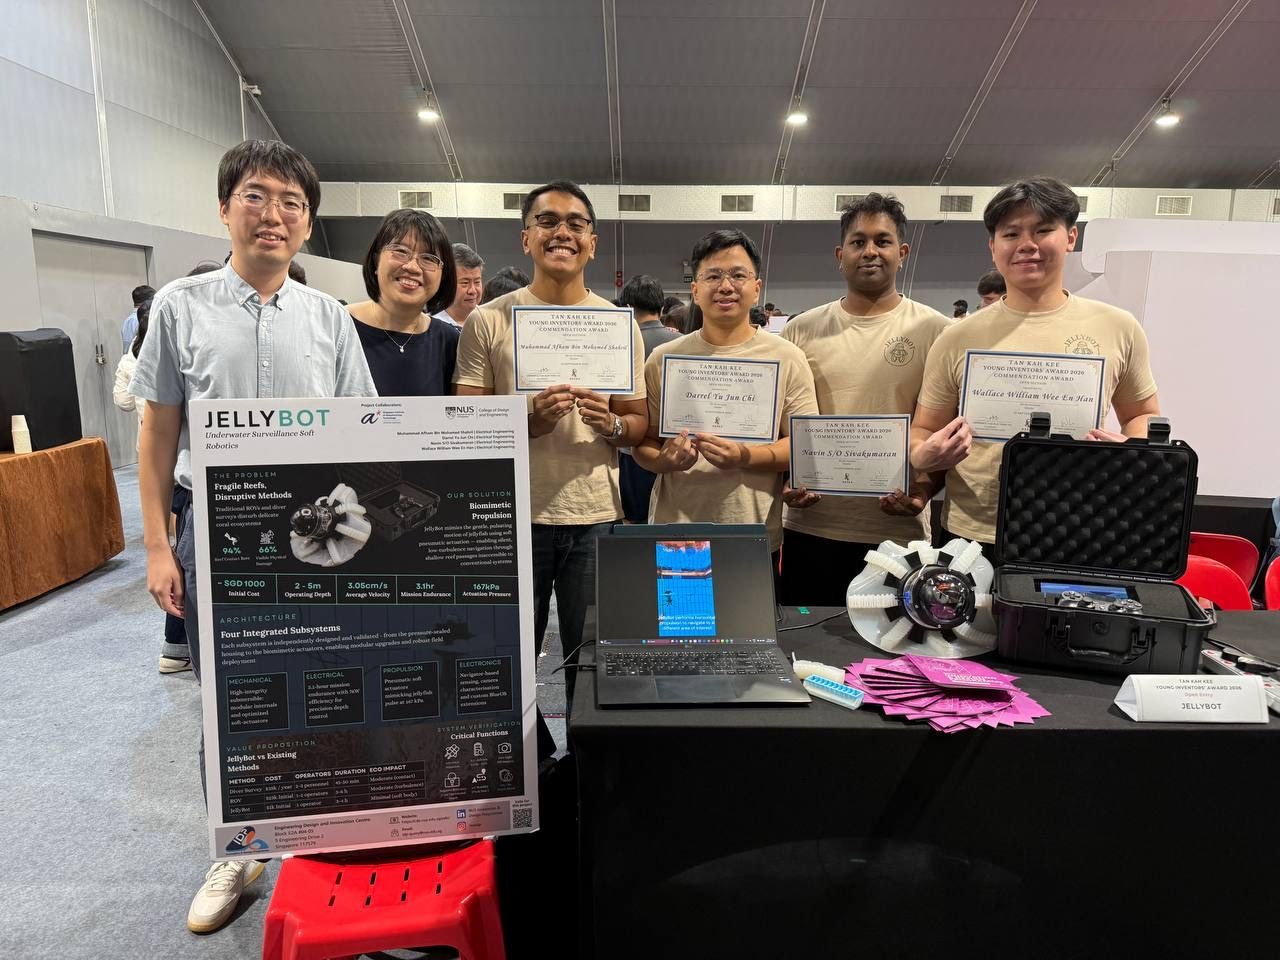
Project Team
Students:
- Darrel Yu Jun Chi (Electrical Engineering, Class of 2026)
- Muhammad Afham Bin Mohamed Shahril (Electrical Engineering, Class of 2026)
- Navin S/O Sivakumaran (Electrical Engineering, Class of 2026)
- Wallace William Wee En Han (Electrical Engineering, Class of 2026)
Supervisors:
- A/Prof Lim Li Hong Idris (lhi.lim@nus.edu.sg)
- Dr Wang Yuzhe (Singapore Institute of Manufacturing Technology)