Industrial mobile manipulator for Innovation & Design Hub
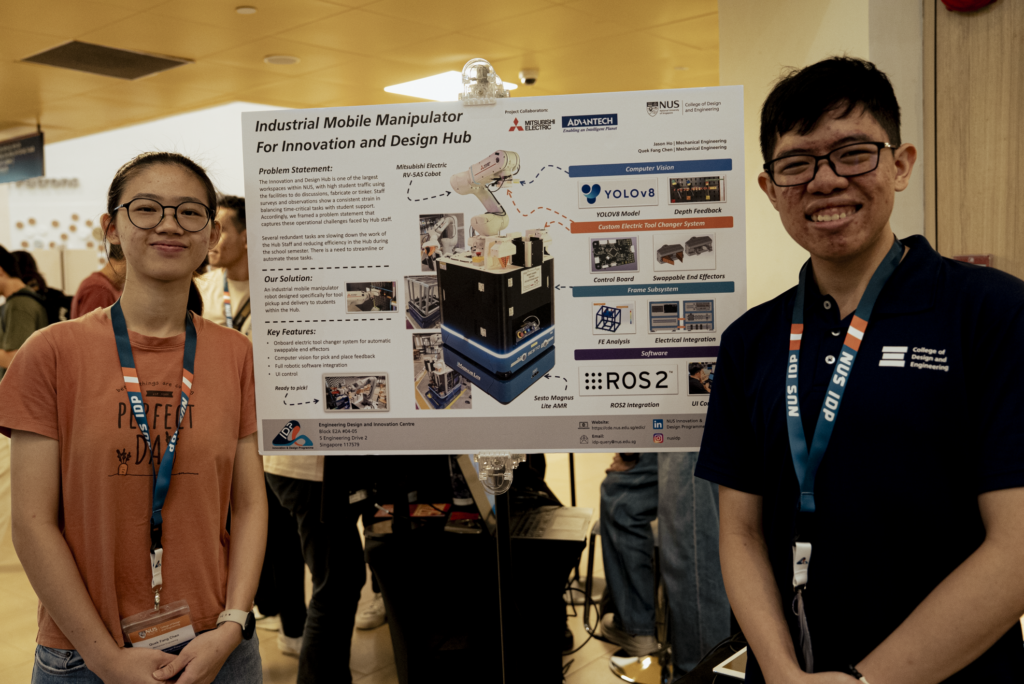
The CDE Innovation and Design Hub is a busy student workspace where staff frequently support activities such as equipment and material collection. Repetitive pick-up and delivery tasks can take up valuable staff time, particularly during peak periods. To address this challenge, the project team developed an industrial mobile manipulator designed to automate logistical tasks within the Hub. CDE4301-industrial-manipulator
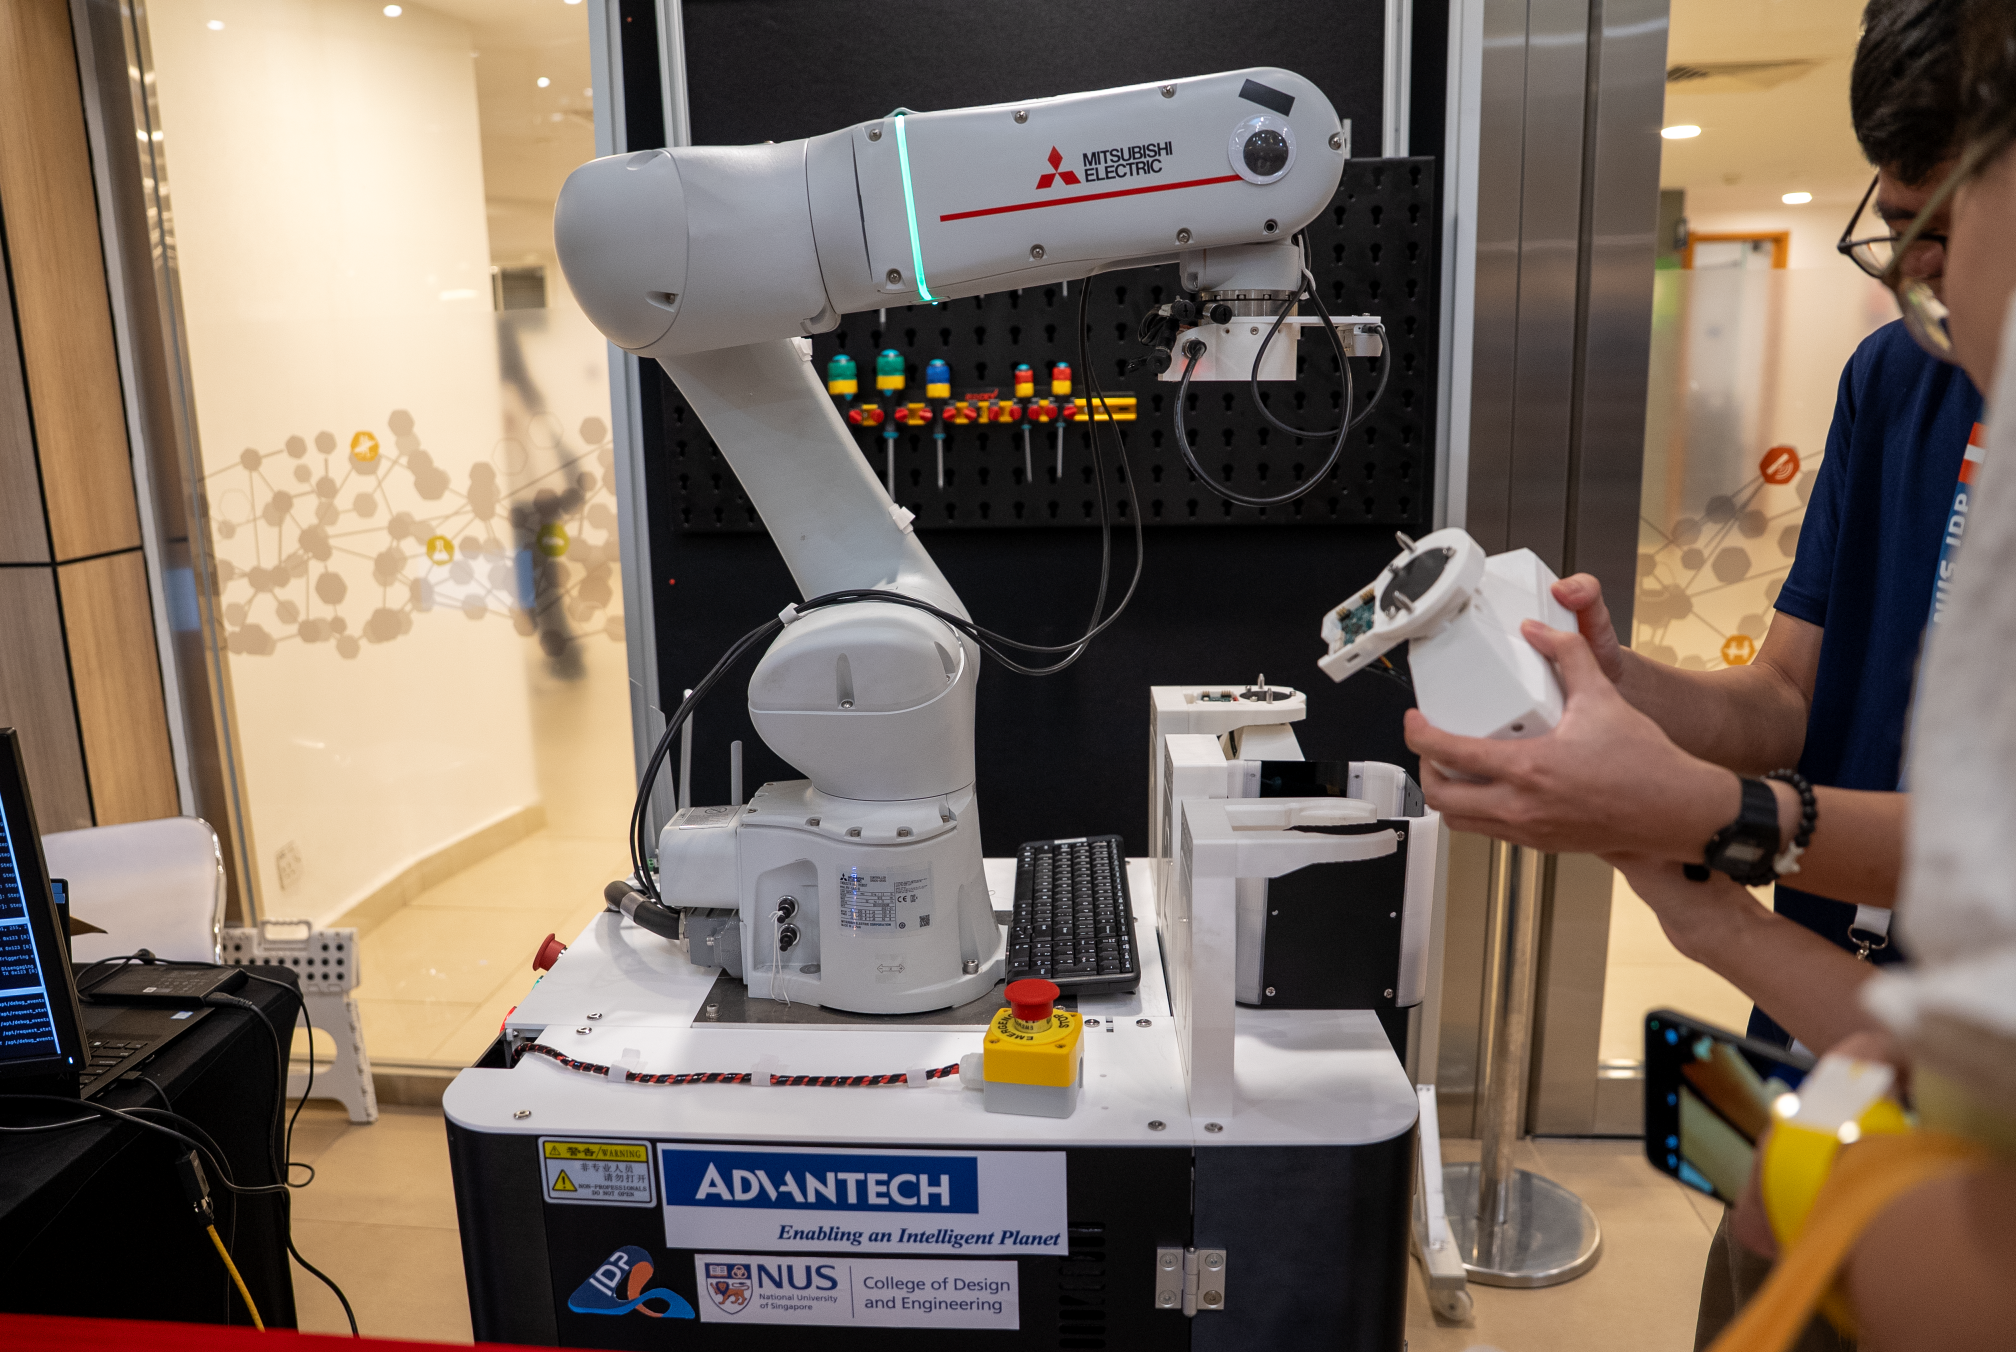
The solution combines a Mitsubishi Electric RV-5AS collaborative robot with a Sesto Magnus Lite autonomous mobile robot (AMR), enabling the system to navigate around the Hub and manipulate objects. Computer vision using YOLOv8 and depth feedback supports object detection and pick-and-place operations, while a custom electric tool-changing system allows the robot to automatically switch between different end effectors. The system also incorporates ROS2 integration and a user interface for operation and control.
By bringing together robotics, computer vision, mechanical design, electronics and software integration, the project demonstrates how autonomous mobile manipulation can streamline routine operations and reduce the workload on Hub staff, freeing them to focus on supporting students and other higher-value activities.
Project Team
Students:
- Jason Ho (Mechanical Engineering, Class of 2026)
- Quek Fang Chen (Mechanical Engineering, Class of 2026)
Supervisors:
- Mr Nicholas Chew (nickchew@nus.edu.sg)
- Mr Graham Zhu (graham.zhu@nus.edu.sg)